Soe Wai Yan
ROBOTICS
I'm an MIT EECS student building perception and manipulation pipelines for real robots — vision-guided arms, autonomous racecars, and embedded sensing systems. I like taking a project from raw camera frames to a physical actuator moving in the real world.
PROJECTS
What I've built
JUNE 2026 – PRESENT
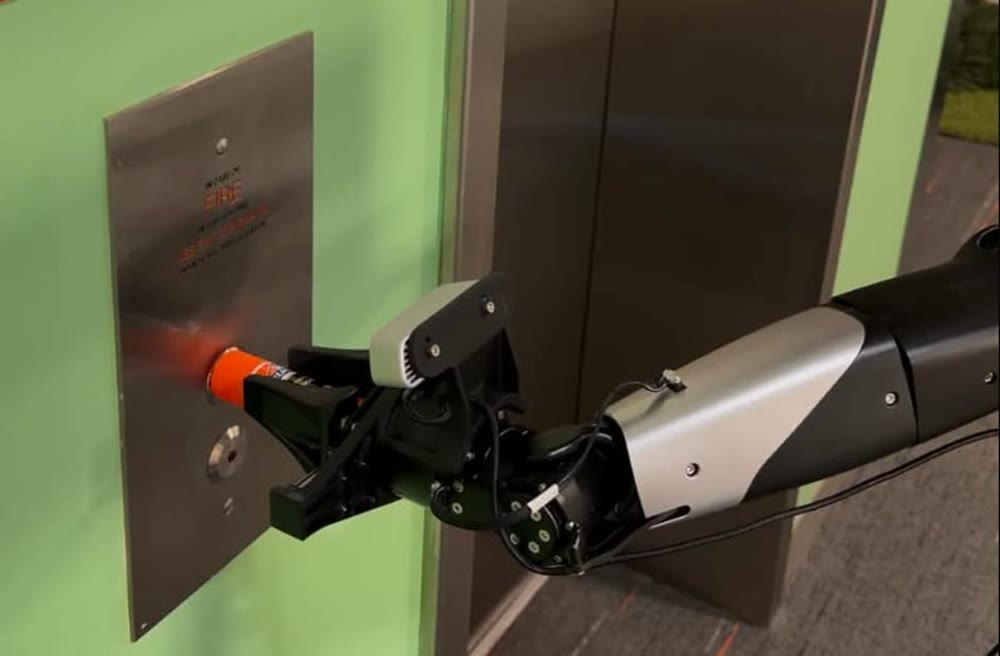
Autonomous Elevator-Button-Press System
A vision-guided pipeline that finds and presses an elevator call button using only a depth camera and a calibrated extrinsic — no fiducial markers, no pre-mapped environment.
JUNE 2026 – PRESENT
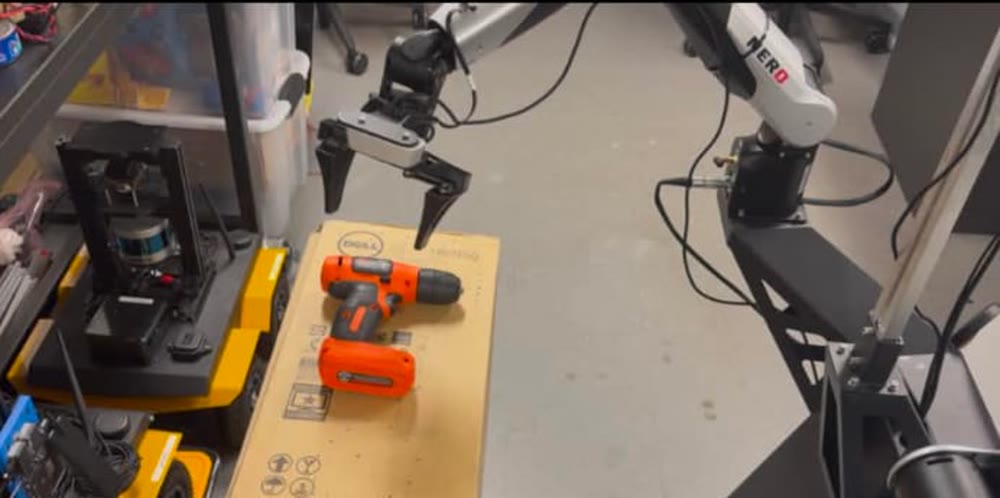
Drill Pick-Up — Diagnosing a VLA Policy in Production
Debugging real-hardware inference for a fine-tuned π0.5 vision-language-action policy picking up a drill with a 7-DoF arm — tracking down an intermittent miss that only showed up on real hardware.
FEB 2026 – MARCH 2026
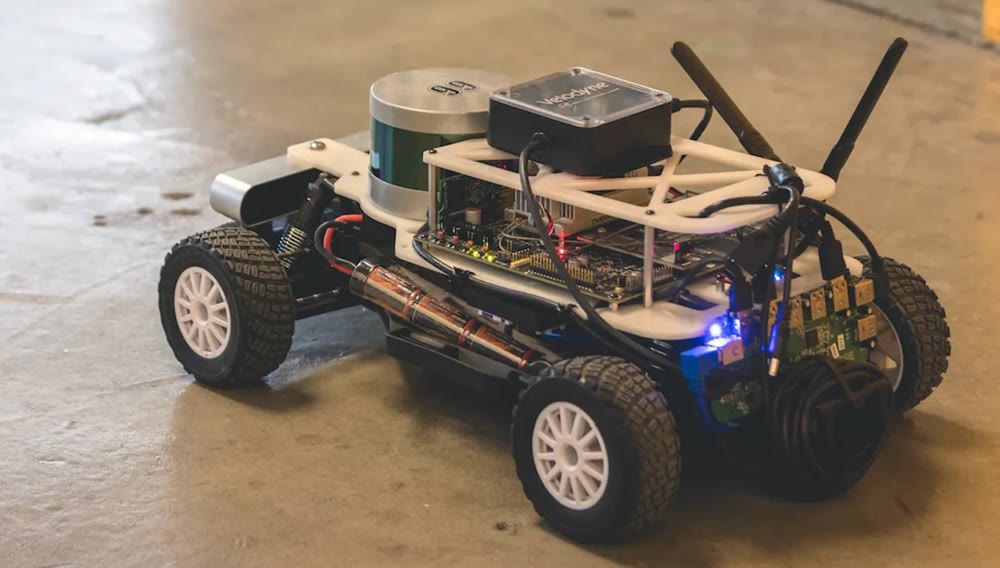
Autonomous Racecar Perception & Control
A full-stack perception, planning, and control system for a physical autonomous racecar, built with a team of 5.
SEPT 2025 – DEC 2025
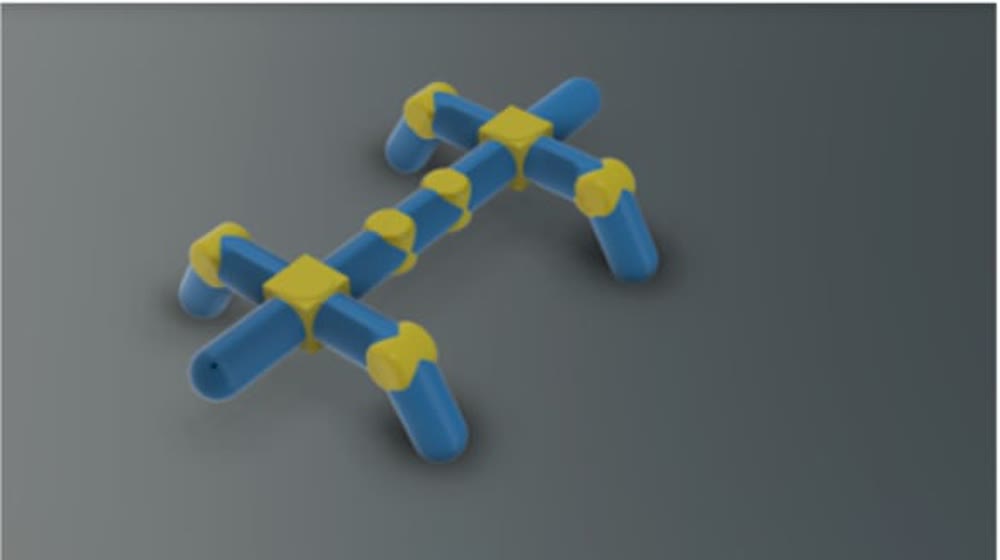
Modular Robot Hardware — MIT CSAIL
Reconfigurable joint and linkage hardware for robot morphology optimization, designed and fabricated at CSAIL.
JUNE 2024 – MAY 2025
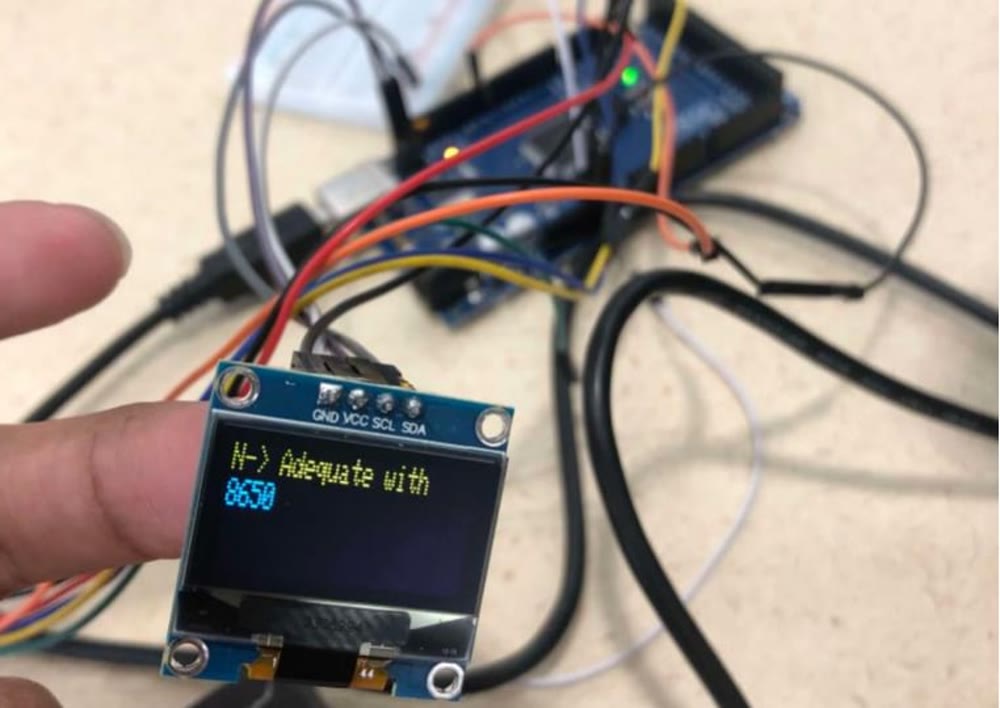
Autonomous Soil-Analysis System — Core Research Program
A calibrated multispectral sensing system for autonomous soil nutrient detection, co-authored as a research paper presented at NCUR 2025.
AUG 2024 – MAY 2025
School Bus Tracking App (BUSMATE)
An affordable IoT-based school bus tracking prototype, built with a team of 4 — 1st place, 2024 Perimeter College Innovative Challenge.
SKILLS